

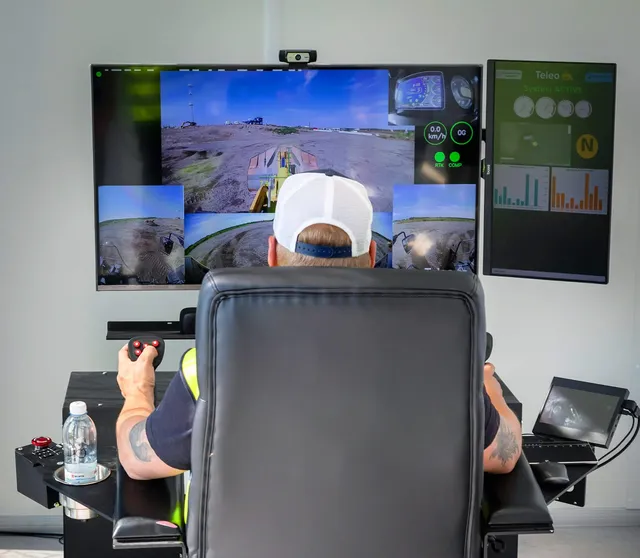
 Teleo Supervised Autonomy
 TeleoBrand-agnostic supervised autonomy retrofit for heavy earthmoving fleets; one operator, multiple machines12 deployments · 4 countries
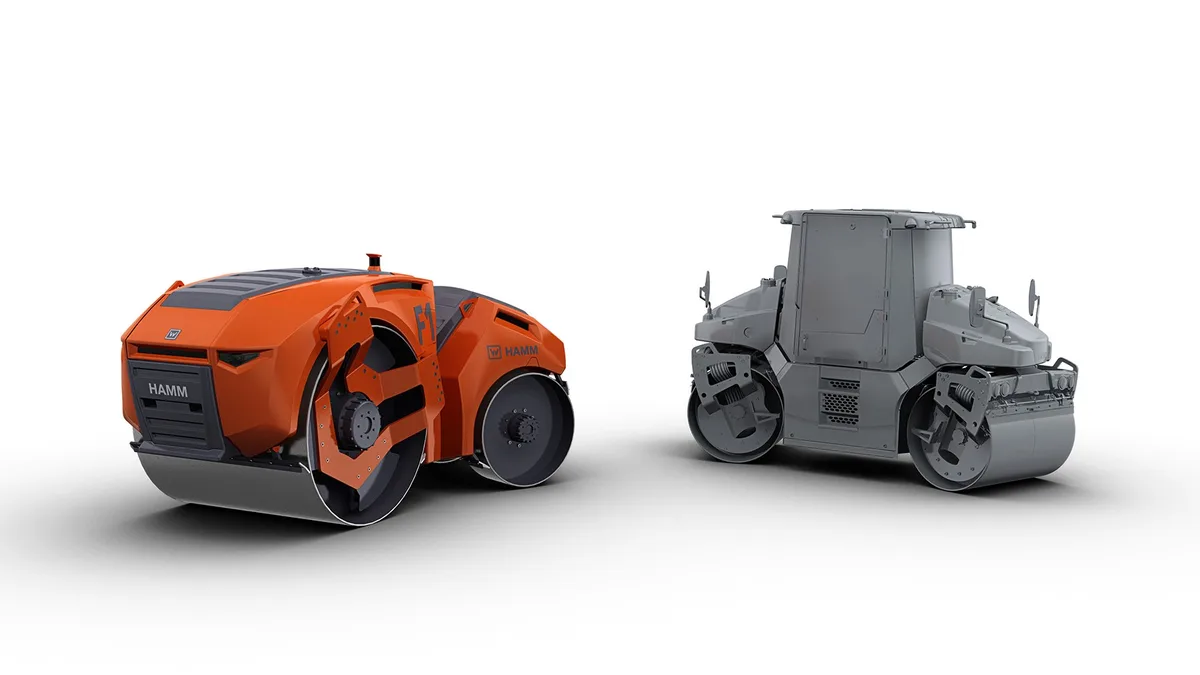 Image: Wirtgen Group (HAMM)

Self-driving compaction roller that completes a programmed route using GNSS positioning
HAMM's Autonomous Roller is a prototype self-driving compaction roller, a large wheeled machine that completes a programmed route without a driver and builds on the GNSS positioning of HAMM's shipping HCQ Navigator. Its target subtasks are compaction of soil and asphalt, compaction in a rolling train, aggregate base placement and subgrade preparation. All running on HAMM's own control system has been on closed test tracks at Tirschenreuth, with over 20,000 operating hours logged since 2014; the one real-site pilot, on Norway's E39 in 2019, used Semcon's autonomy system on a HAMM H25i with a safety operator in the cab.
On closed test tracks, HAMM's prototypes complete a specified program without a driver, drive themselves to refueling points and park when the program ends. A shadowing-roller version follows a simulated road paver, holding lanes and speed windows, braking to avoid over-compaction and changing compaction lanes precisely to prevent deformation. The positioning base is the HCQ Navigator, HAMM's shipping GNSS system that shows on current HAMM compactors where an area was compacted and how often.
In a rolling train the roller works behind the paver, and HAMM's shadowing roller does that on the test track: it follows a simulated road paver with no driver. For two rollers on the same ground, HAMM designed a collision monitoring system around a second test track where both drive at once. On a real paving train the roller drivers stay in the cab, which HAMM states holds until surroundings monitoring is precise enough for driverless work.
Subgrade Preparation
Image: Wirtgen Group (HAMM)Autonomous Roller
3 deployments · 2 companies · 2 countries
As the maker states it.
Teleo Supervised AutonomyTeleoBrand-agnostic supervised autonomy retrofit for heavy earthmoving fleets; one operator, multiple machines12 deployments · 4 countries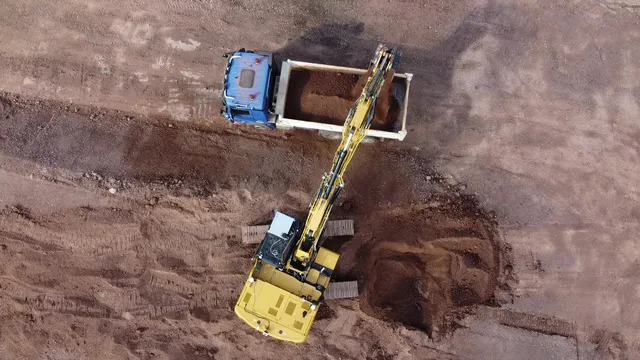 Gravis RACK
 Gravis RoboticsRetrofit autonomy kit for excavators and wheel loaders; bucket-based earthmoving tasks6 deployments · 2 countries
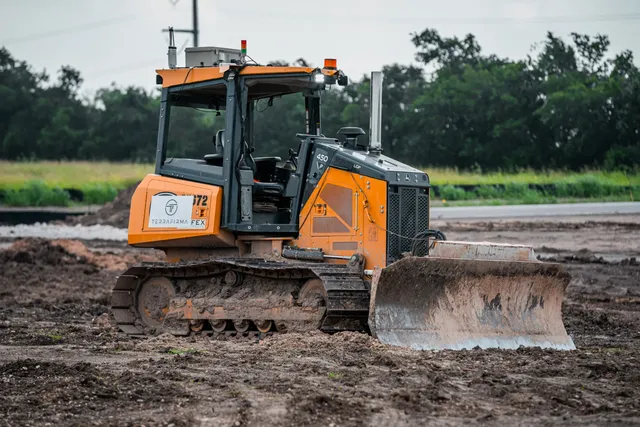 Image: TerraFirma, Inc.TerraFirma Autonomous Earthmoving Platform
 TerraFirmaRetrofit kit that makes excavators, dozers, loaders and graders remote-operated or semi-autonomous6 deployments · 1 country
 AIM Platform
 AIMFully autonomous earthmoving retrofit; bulldozers and excavators, zero-entry worksites5 deployments
 Exosystem
 Built RoboticsAftermarket excavator retrofit for autonomous utility trenching on solar and energy sites4 deployments · 2 countries
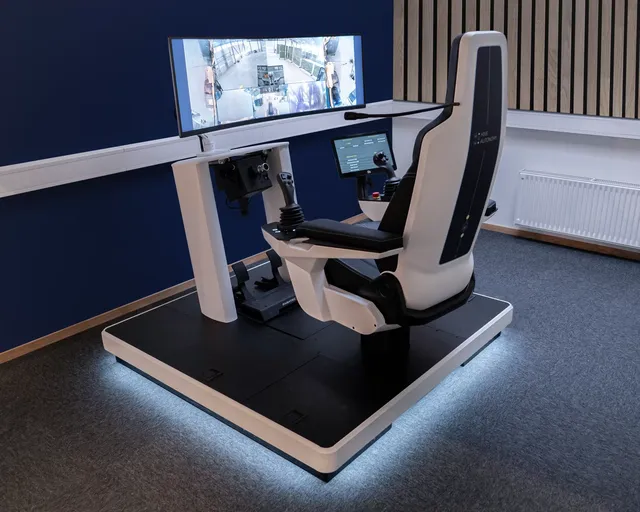 Hive Machine Intelligence Equipment
 HIVE5G-dependent retrofit kit for remote-operated loaders and excavators3 deployments · 1 countryTeleo Supervised AutonomyTeleoBrand-agnostic supervised autonomy retrofit for heavy earthmoving fleets; one operator, multiple machines12 deployments · 4 countriesImage: TerraFirma, Inc.TerraFirma Autonomous Earthmoving PlatformTerraFirmaRetrofit kit that makes excavators, dozers, loaders and graders remote-operated or semi-autonomous6 deployments · 1 countryAIM PlatformAIMFully autonomous earthmoving retrofit; bulldozers and excavators, zero-entry worksites5 deployments
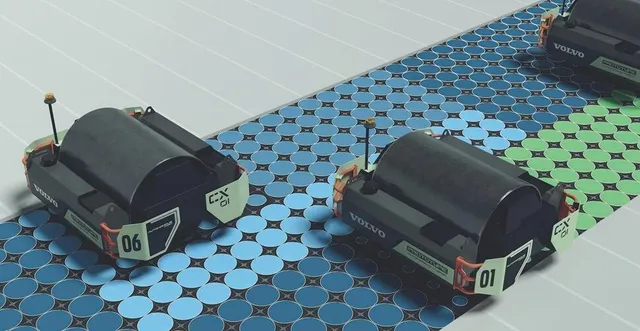 Image: Volvo Construction EquipmentCX01
 Volvo Construction EquipmentElectric hybrid split-drum compactor; autonomous and fleet-coordinated by design2 deployments · 2 countries
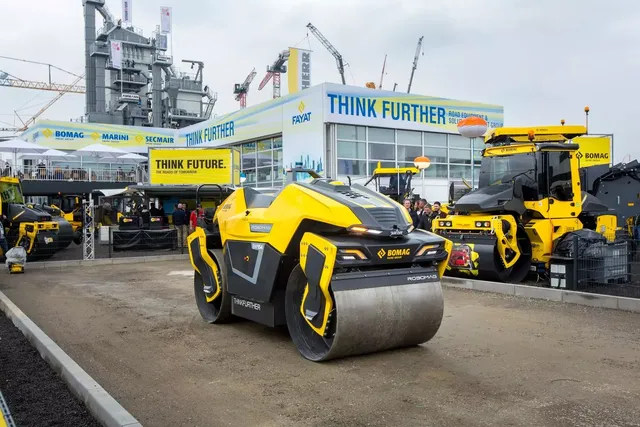 Image: BOMAG GmbHBOMAG ROBOMAG
 BOMAGRemote-controlled tandem roller with emergency braking for soil and asphalt compaction0 deployments
Something wrong? How corrections work